
Aman Nindra
ML Systems • Robotics • AI Infrastructure
Third-year Data Science student at UC San Diego interested in computer vision, NLP, and efficient machine learning on real hardware.
About Me
Hi, I’m Aman Nindra, a third-year Data Science student at UC San Diego. I’m interested in computer vision, natural language processing, and making machine learning models run more efficiently.
Previously, I worked on computer vision for autonomous vehicles, developing lane and object detection models for an autonomous bicycle. I enjoy taking models beyond experiments and getting them to work on real hardware.
Education
University of California, San Diego
Bachelor of Science, Data Science
University of California, Merced
Computer Science and Engineering
Experience
Data Science Intern • Livermore, CA
Lawrence Livermore National Laboratory
July 2026 – August 2026
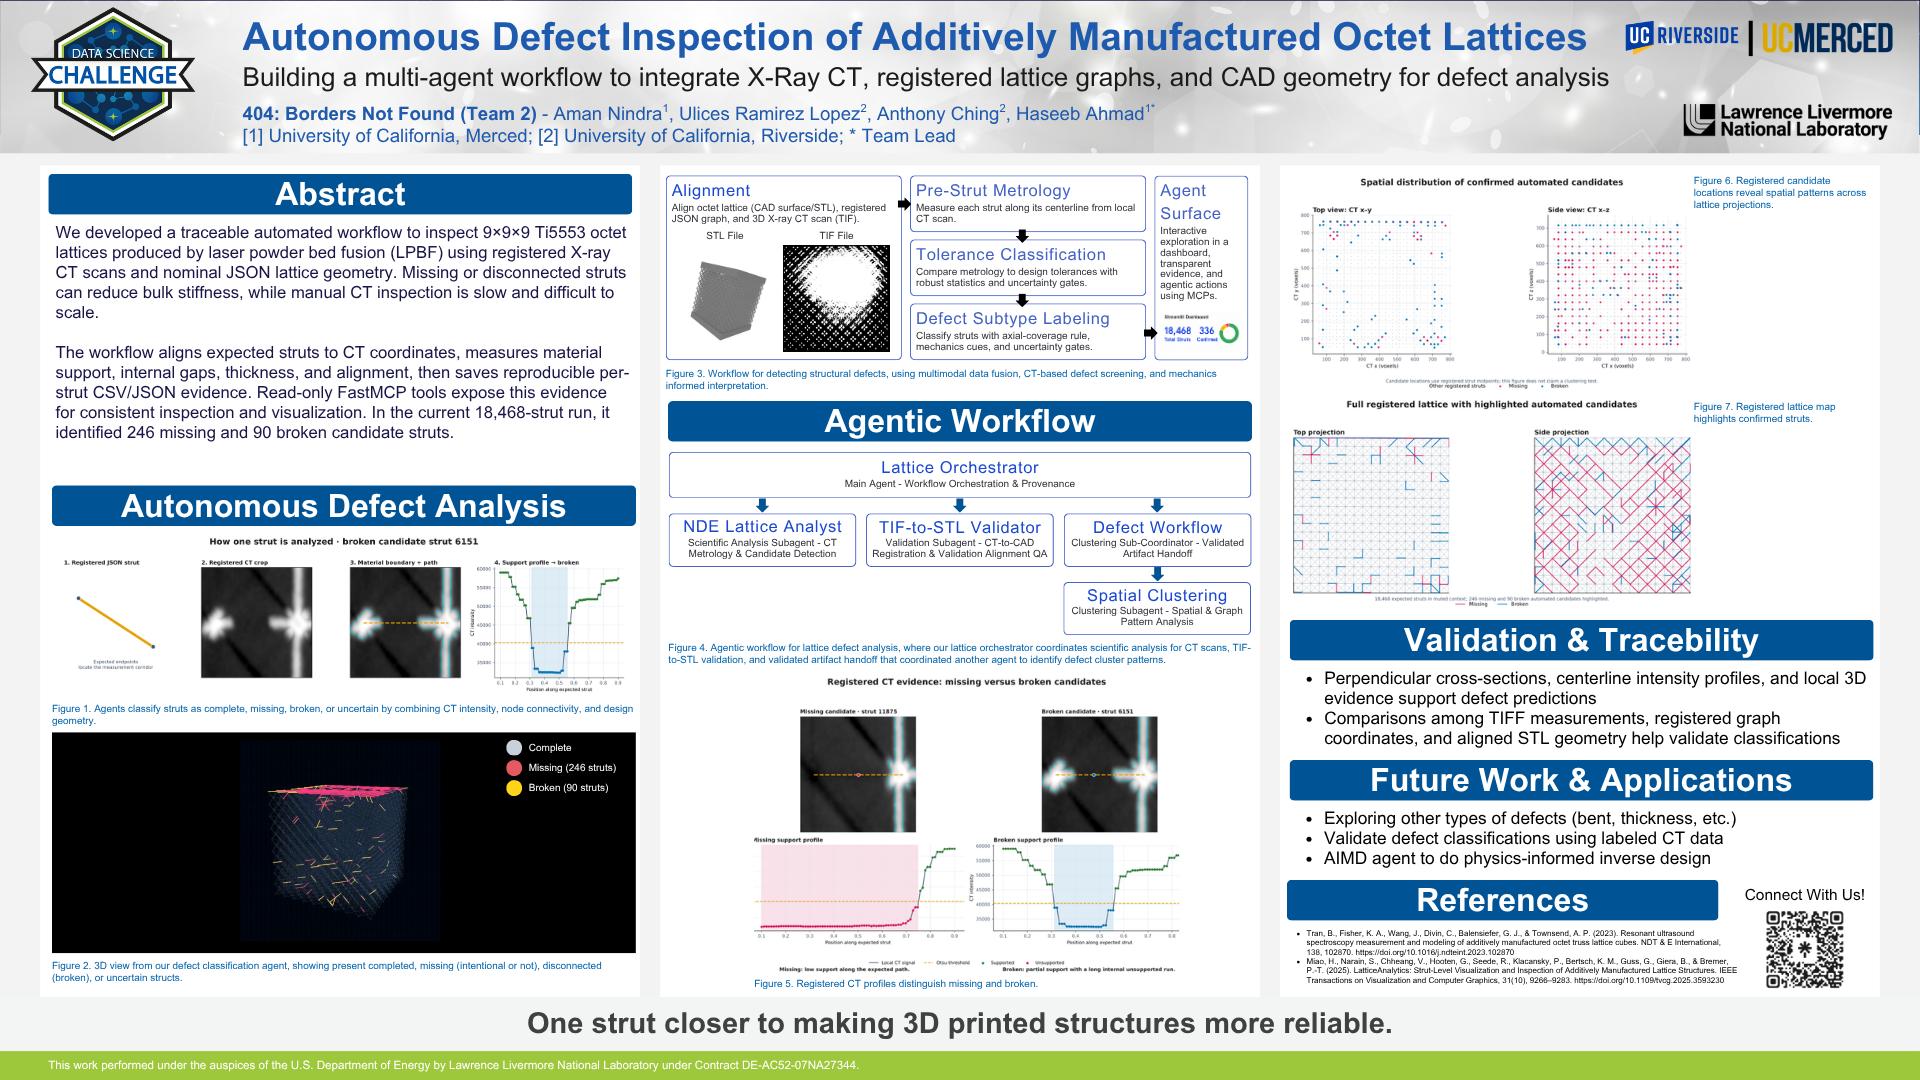
- Built the core of a multi-agent scientific AI system for detecting defects in additively manufactured metal lattices, aligning volumetric X-ray CT scans with nominal 3D design geometry and automatically measuring and classifying structural components.
- Automatically analyzed all 18,468 struts in a lattice scan against its nominal design, identifying 118 missing and 256 broken candidate struts with results traceable to the original CT volume.
- Extended an open-source 3D scientific-computing pipeline with image segmentation, geometric alignment, centerline analysis, and skeletonization, and built an interactive Streamlit and Three.js interface for reviewing defect candidates.
PythonComputer VisionThree.jsStreamlitScientific Computing
Undergraduate Researcher at R&D Lab • Merced, CA
University of California, Merced
May 2026 – Present

- Built a real-time autonomous-vehicle perception pipeline using LaneATT with a ResNet-34 backbone, improving CULane lane-detection F1 from 0.77 to 0.79 through custom data augmentation.
- Trained a YOLOv11n object detector for pedestrians, vehicles, traffic lights, and stop signs by adapting the COCO dataset, achieving 0.650 mAP50 and 0.465 mAP50-95.
- Profiled and optimized deep-learning inference on an NVIDIA Jetson Orin Nano Super, benchmarking ONNX Runtime with CUDA against TensorRT FP16 and reducing LaneATT latency by 4.55× (125.7 ms to 27.6 ms) and YOLO latency by 1.83× (30.3 ms to 16.6 ms).
PyTorchLaneATTYOLOv11SLURMROS 2Jetson Nano SuperESP32-S3Computer VisionTensorRTONNX RuntimeCUDAModel Quantization
Software Engineering Intern • Remote
Valley Institute for Sustainability, Technology & Agriculture
May 2026 – August 2026
- Architected a GPU-accelerated machine-learning platform on a 3-node Kubernetes cluster with 70 TB of persistent storage and 2 GPU worker nodes, enabling 40+ professors and 50+ PhD researchers to train computer vision and NLP models.
- Built Terraform-based development environments that allowed researchers to configure CPU, RAM, and NVIDIA GPU allocations and provision reproducible PyTorch, TensorFlow, and Conda workloads through browser-based or remote VS Code environments.
KubernetesTerraformPostgreSQLAWSLinux
Machine Learning Intern
Machine Learning Club
Jan 2026
- Fine-tuned BERT for multi-label emotion classification across 28 categories on 206K Reddit comments, reaching 0.712 Macro F1 and 97.0% label-wise accuracy over 25 training epochs.
- Developed per-class threshold calibration using grid search across 0.01–0.99 for each output label, replacing a single global decision threshold and improving prediction quality for minority emotion classes.
- Built an evaluation pipeline measuring Macro F1, Jaccard similarity, label-wise accuracy, and exact-set accuracy, achieving 0.688 Jaccard similarity and predicting the complete correct emotion set for 47.7% of samples.
PyTorchTransformersscikit-learnNLP
Machine Learning Intern
Data Science Society
Nov 2025 – Feb 2026
- Placed 4th on DrivenData's wildlife camera-trap leaderboard, reducing competition log loss from 2.18 to 0.67 by fine-tuning a 300M-parameter EVA-Large vision transformer to classify 8 African species across 16,488 images.
- Trained EVA-Large using PyTorch (DDP) and mixed-precision training across 4 NVIDIA Tesla V100 GPUs on AWS SageMaker, achieving 93.3% validation accuracy.
- Built a per-class evaluation harness measuring precision, recall, F1, and top-3 accuracy every epoch, identifying blank-frame misclassification as the dominant error source and the only class remaining below 0.80 F1 across all four evaluated architectures.
PyTorchVision TransformersDDPAWS SageMaker
Technical Skills
ML Systems
PyTorchTensorRTONNX RuntimeComputer VisionNatural Language ProcessingTransformersYOLONumPyPandasMatplotlibscikit-learnOpenCV
Robotics & Vision
NVIDIA JetsonJetPackROS 2Real-Time InferenceGPU Performance ProfilingDistributed Training
Backend & Infrastructure
AWSGoogle CloudLinuxDockerKubernetesSlurmTerraformFastAPIFlask
Frontend
React.jsNext.jsThree.jsGitFirebase
Languages
PythonC++CJavaScript/TypeScriptSQLBash/Shell